01ROBOT HARDWARE
Low-reduction, high-torque actuators and an endoskeleton structure
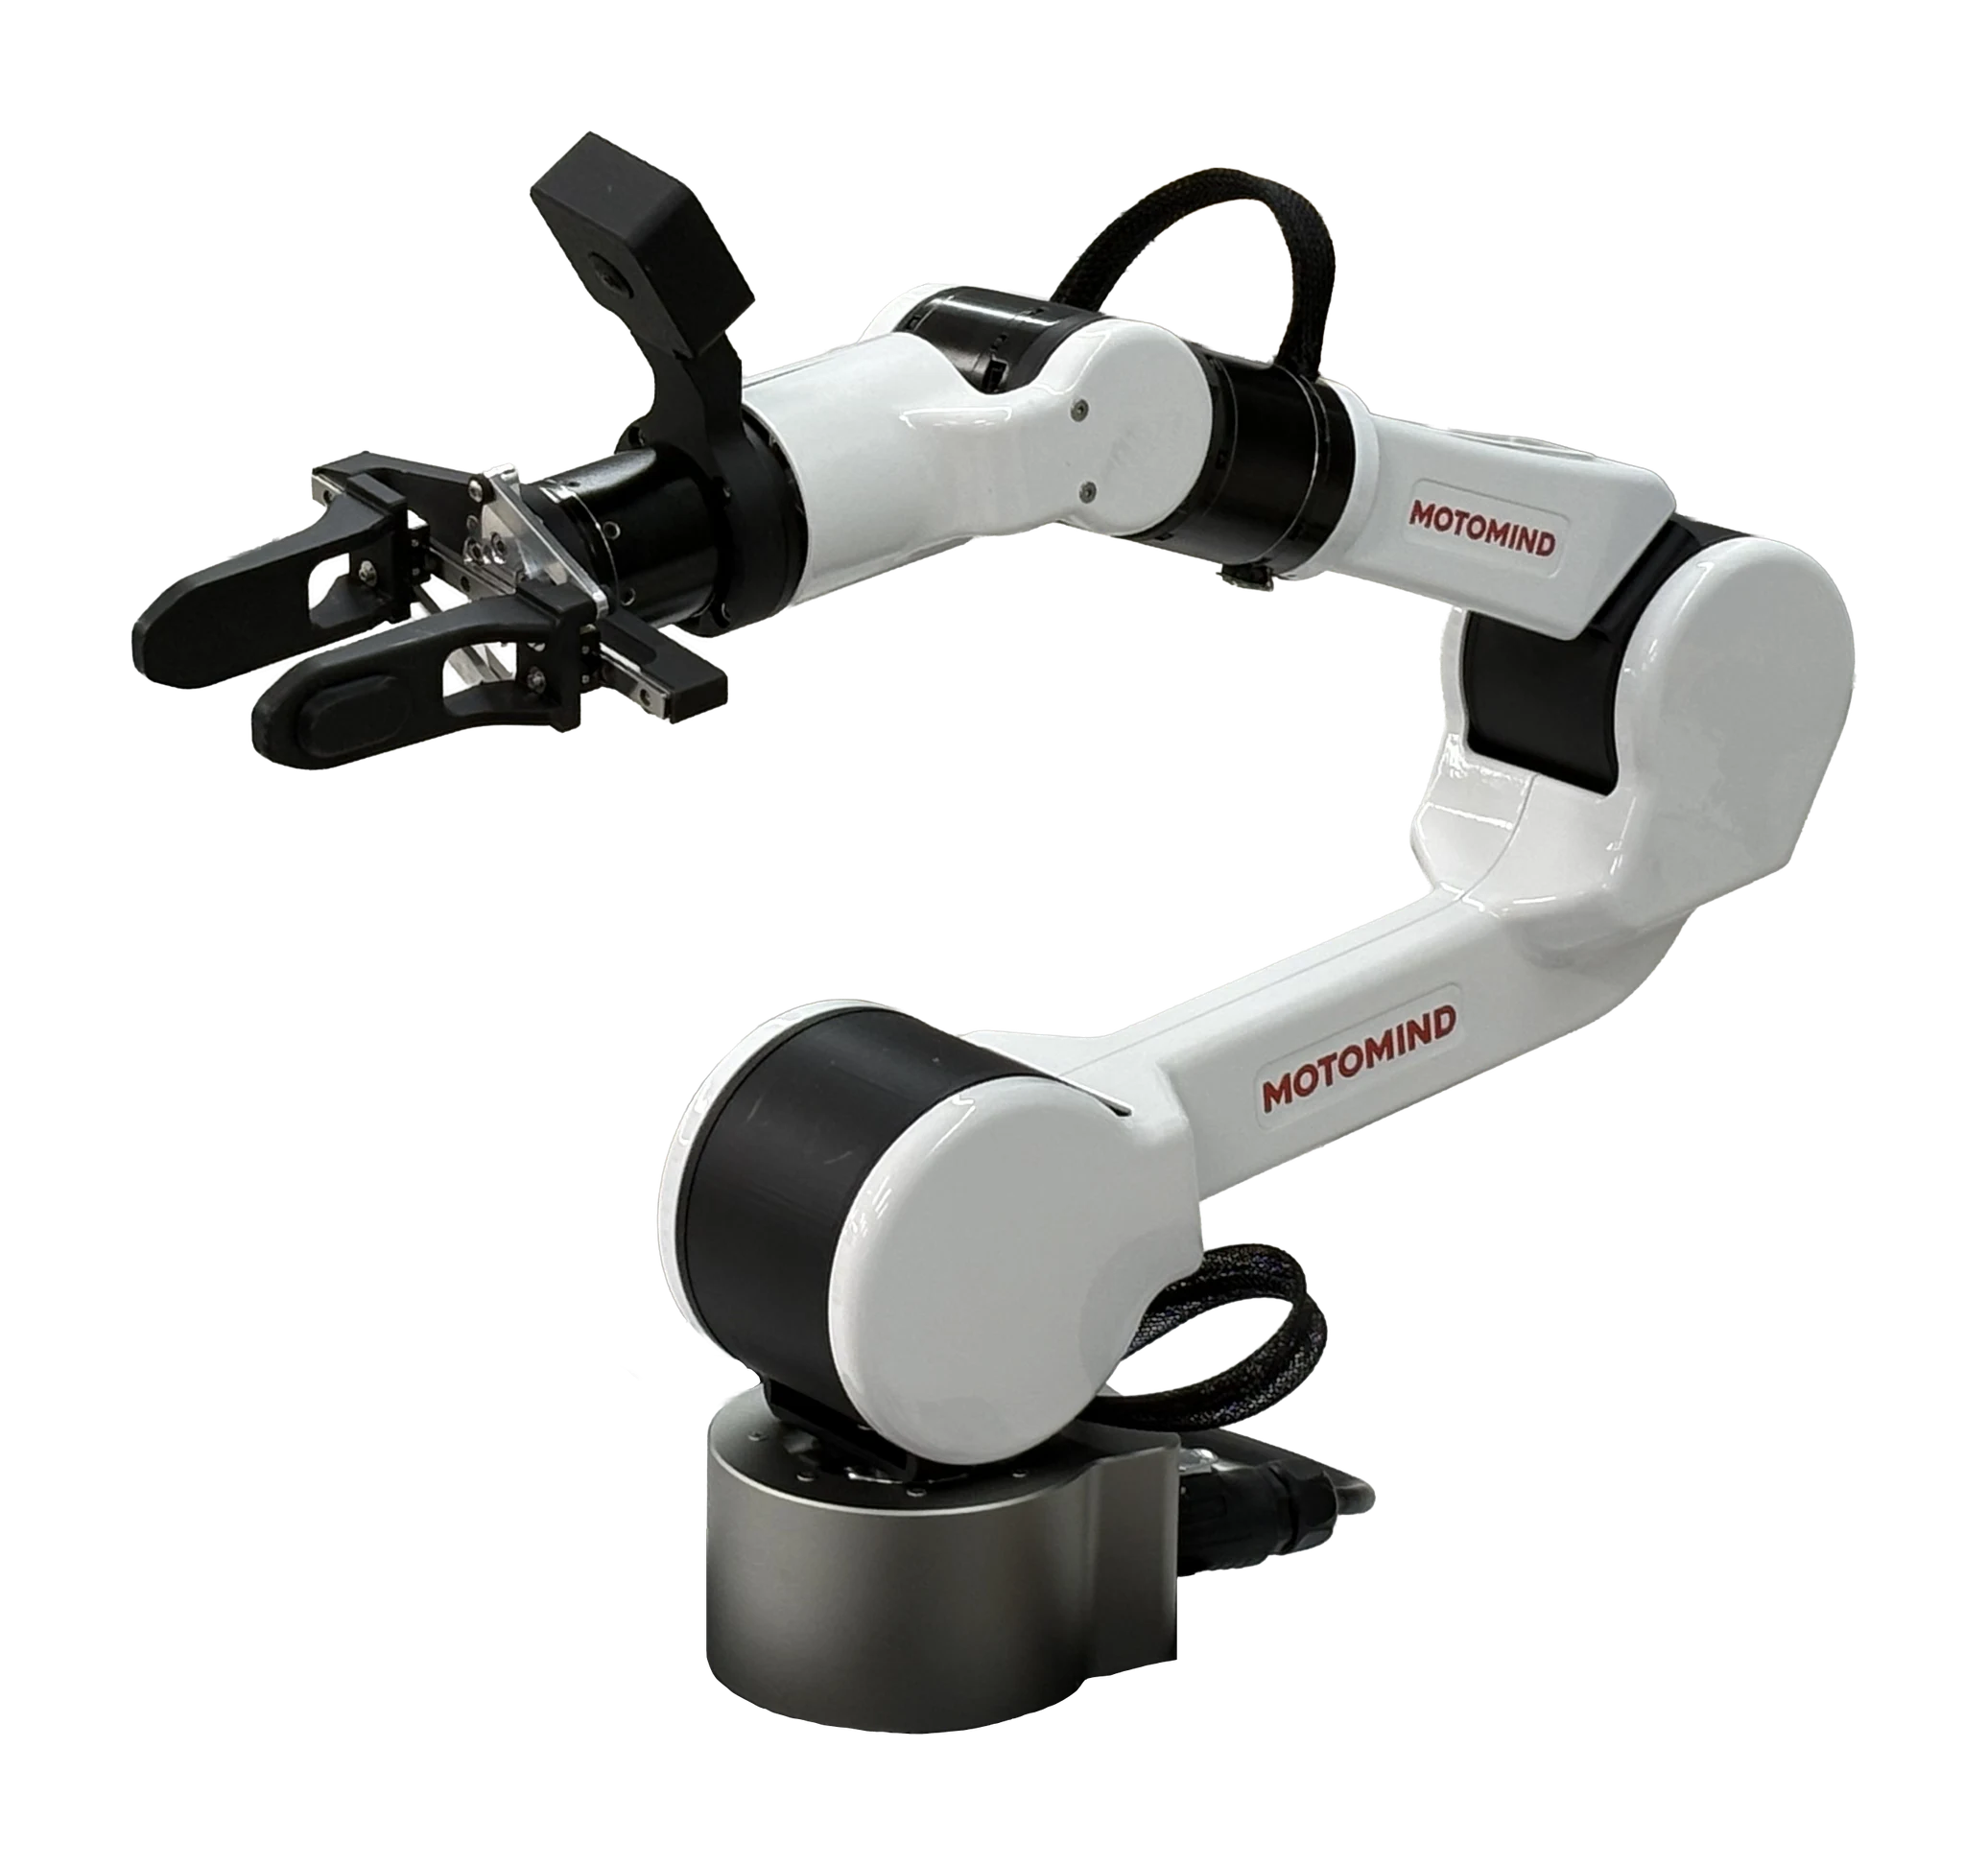
Pancake-motor actuators with low gear reduction keep reflected inertia low and preserve backdrivability. Arms are built as an endoskeleton rather than an exoskeleton, cutting volume and cost, and the same actuator modules are reused from the MILLY arm to the BELLO and BELLO mini humanoids.
- Actuator
- Pancake BLDC · low reduction, high torque
- Structure
- Endoskeleton arm · shared modules throughout
- Humanoids
- BELLO 170 cm · BELLO mini 140 cm, 30 DoF
- Arm
- MILLY 6+1 DoF · 3 kg payload
- Locomotion
- RL-based bipedal walking (NextRise 2026 demo)