
MILLY — Endoskeleton AI robot arm
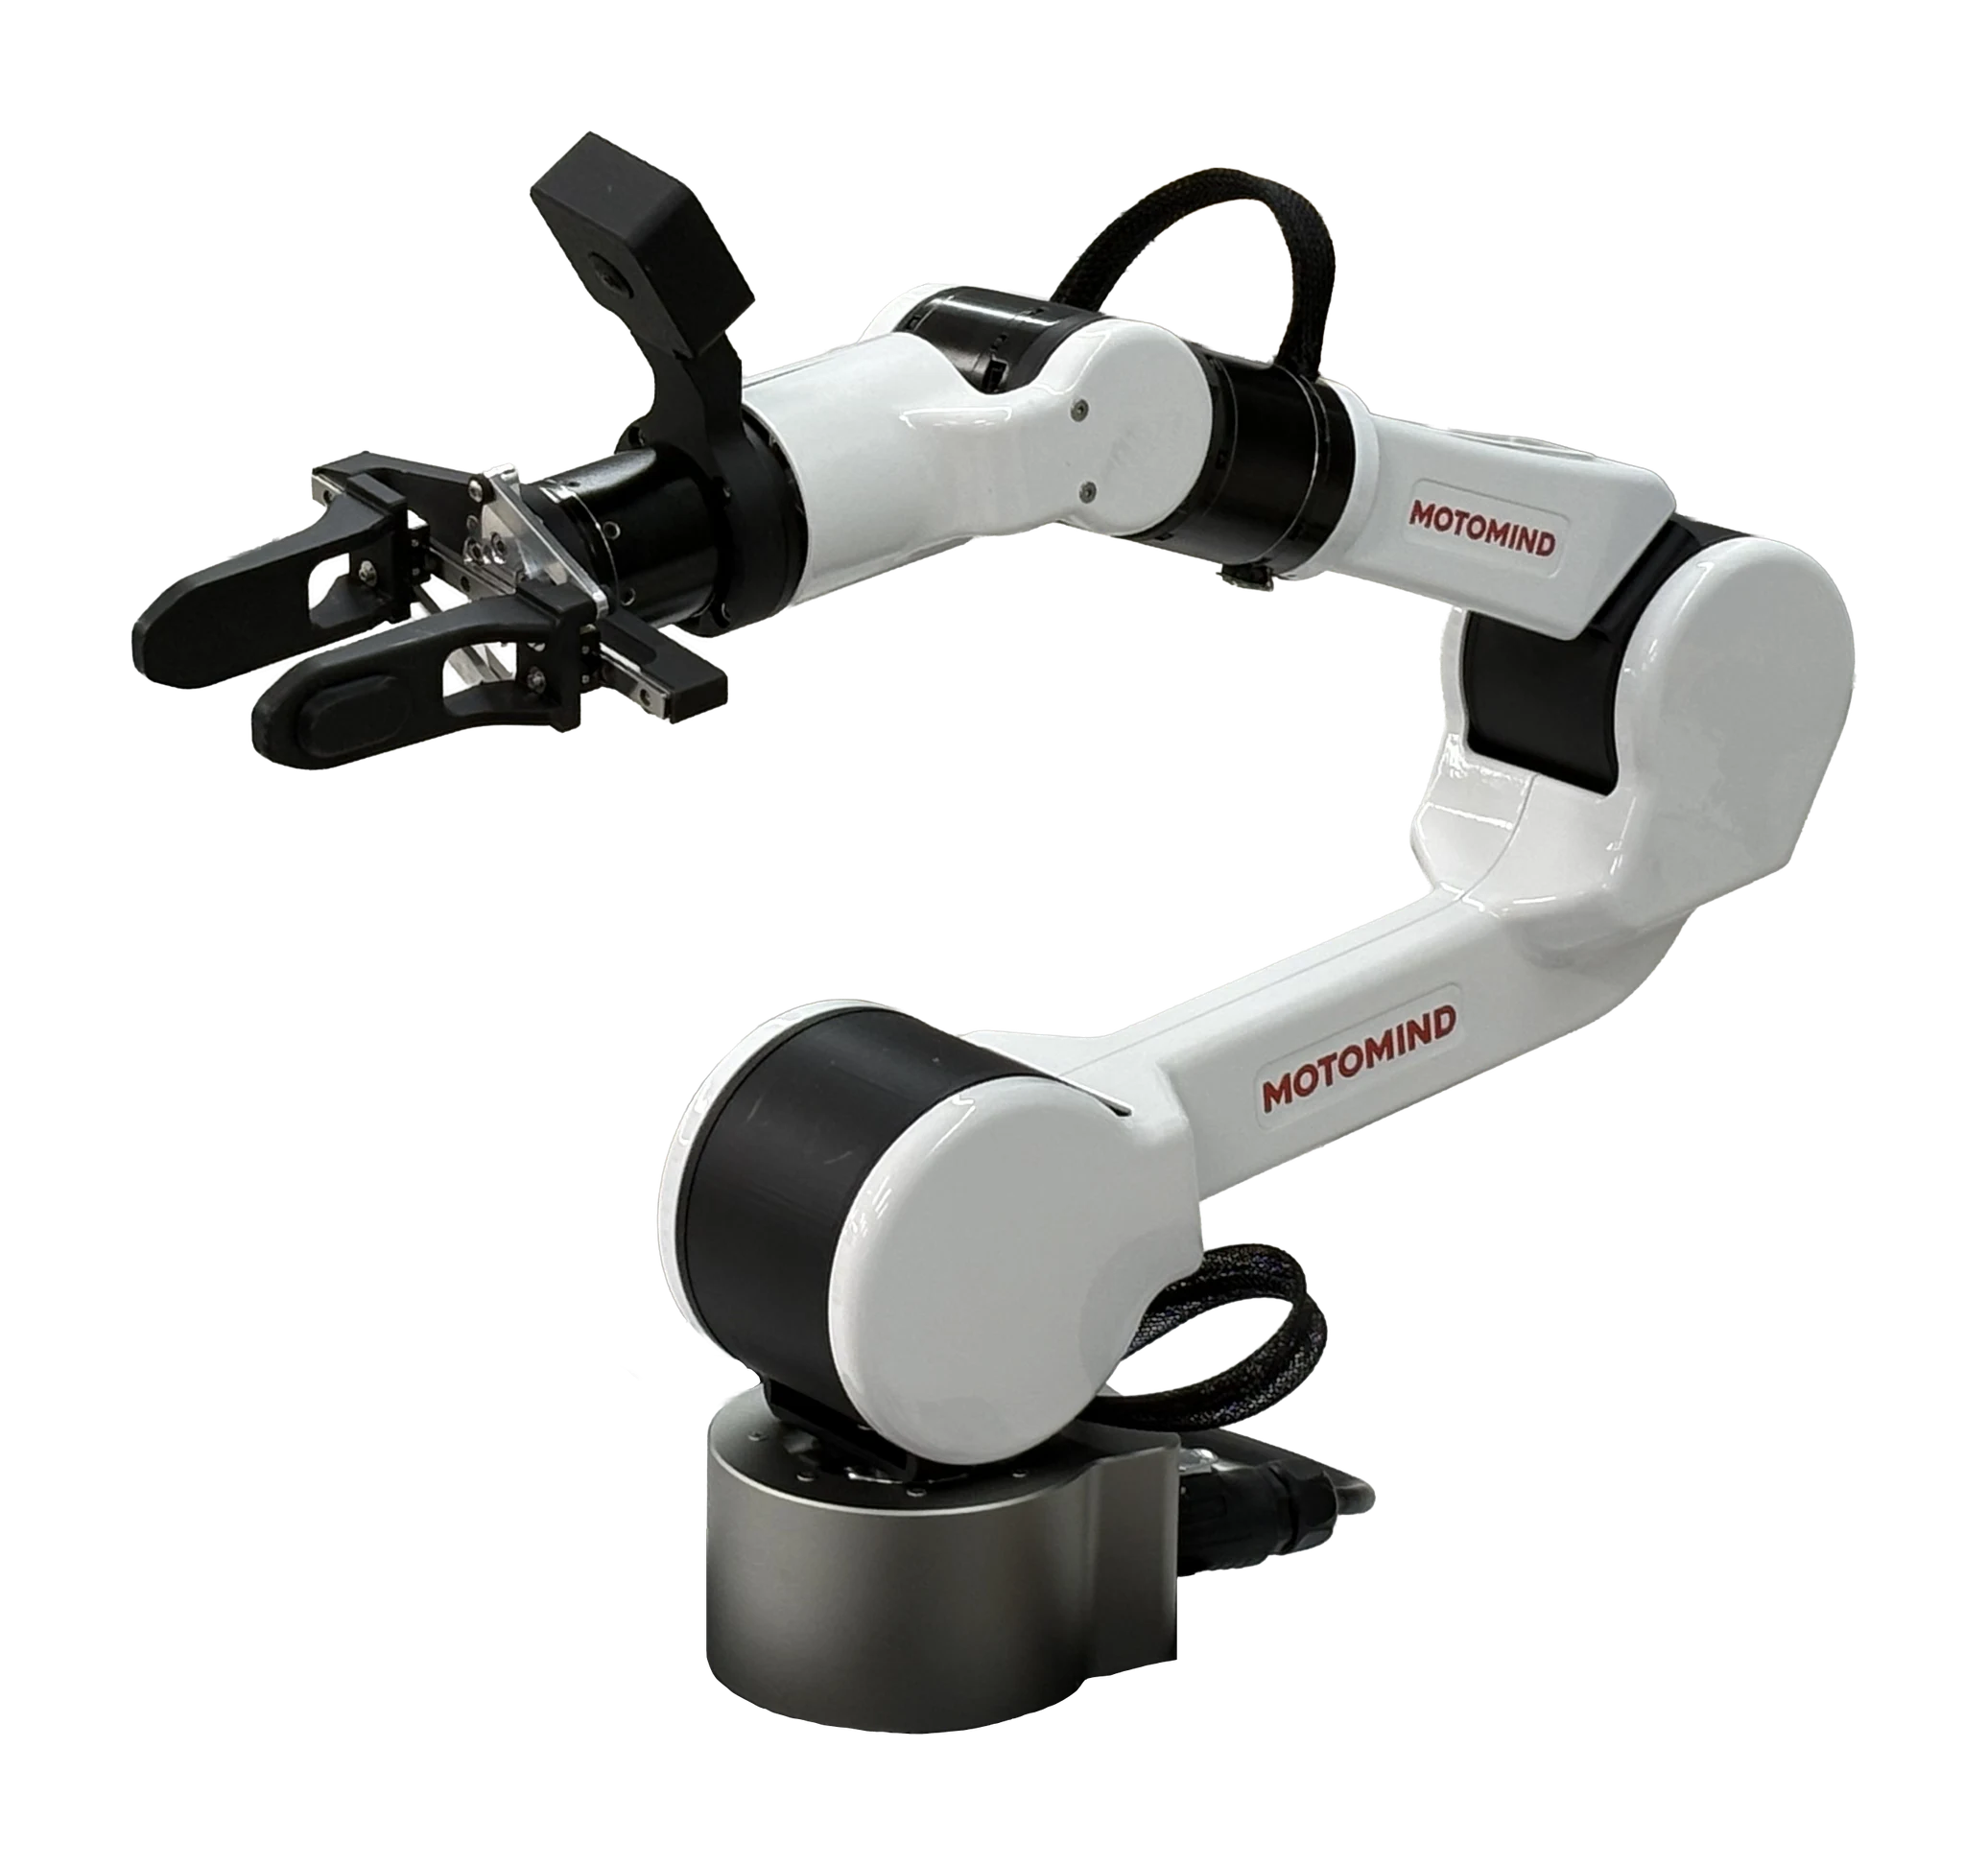
An in-house designed and manufactured 6+1 DoF AI robot arm with an endoskeleton (internal-skeleton) structure. Low-ratio actuators provide fast response and smooth torque control for manipulation validation and real-world data collection. Task logic built on MILLY runs unchanged on BELLO through the common SDK and shared Runtime.
Specifications
Shipped as a single 6+1 DoF arm — six joints plus one gripper/tool axis — for fixed workstations or mobile-base integration.
Key features
Compact endoskeleton
An internal skeleton (rather than an exoskeleton) reduces external volume, allowing the arm to drop into tight workspaces or operator-adjacent setups without redesigning the line.
High-response actuator
Low gear ratios deliver fast response and smooth torque control simultaneously, with torque-based auto-stop on collision.
Flexible integration
Scale from a fixed workstation to a mobile base or full humanoid integration using the same module — a smooth path for staged automation.
Joint motion range
- J1±170°180°/sBase
- J2−90° to +135°180°/sShoulder
- J3±170°180°/s
- J4−110° to +110°200°/s
- J5±170°200°/s
- J6±115°220°/s+1 axis: gripper/tool
System composition
Frame, actuators, controller interface, and gripper attachment ship as one integrated module — no additional sourcing required for first deployment.
Endoskeleton frame
An internal skeleton reduces external exposure, lowering the risk of collisions with operators and keeping the form factor compact enough for tight production lines.
BLDC actuator module
In-house low-ratio BLDC actuators deliver both fast response and smooth torque control, covering precision assembly and rapid pick-and-place from a single module.
Gripper attachment
A standard mount lets you swap pick-and-place, assembly, or inspection grippers on the same arm to match the process at hand.
Control interface
Direct integration with the MOTOMIND AI Board plus a standard interface for third-party controllers — works alongside existing systems.
Applications
From manipulation validation and real-world data collection to service-robot integration — wherever fast iteration matters.
VLA · imitation-learning data collection
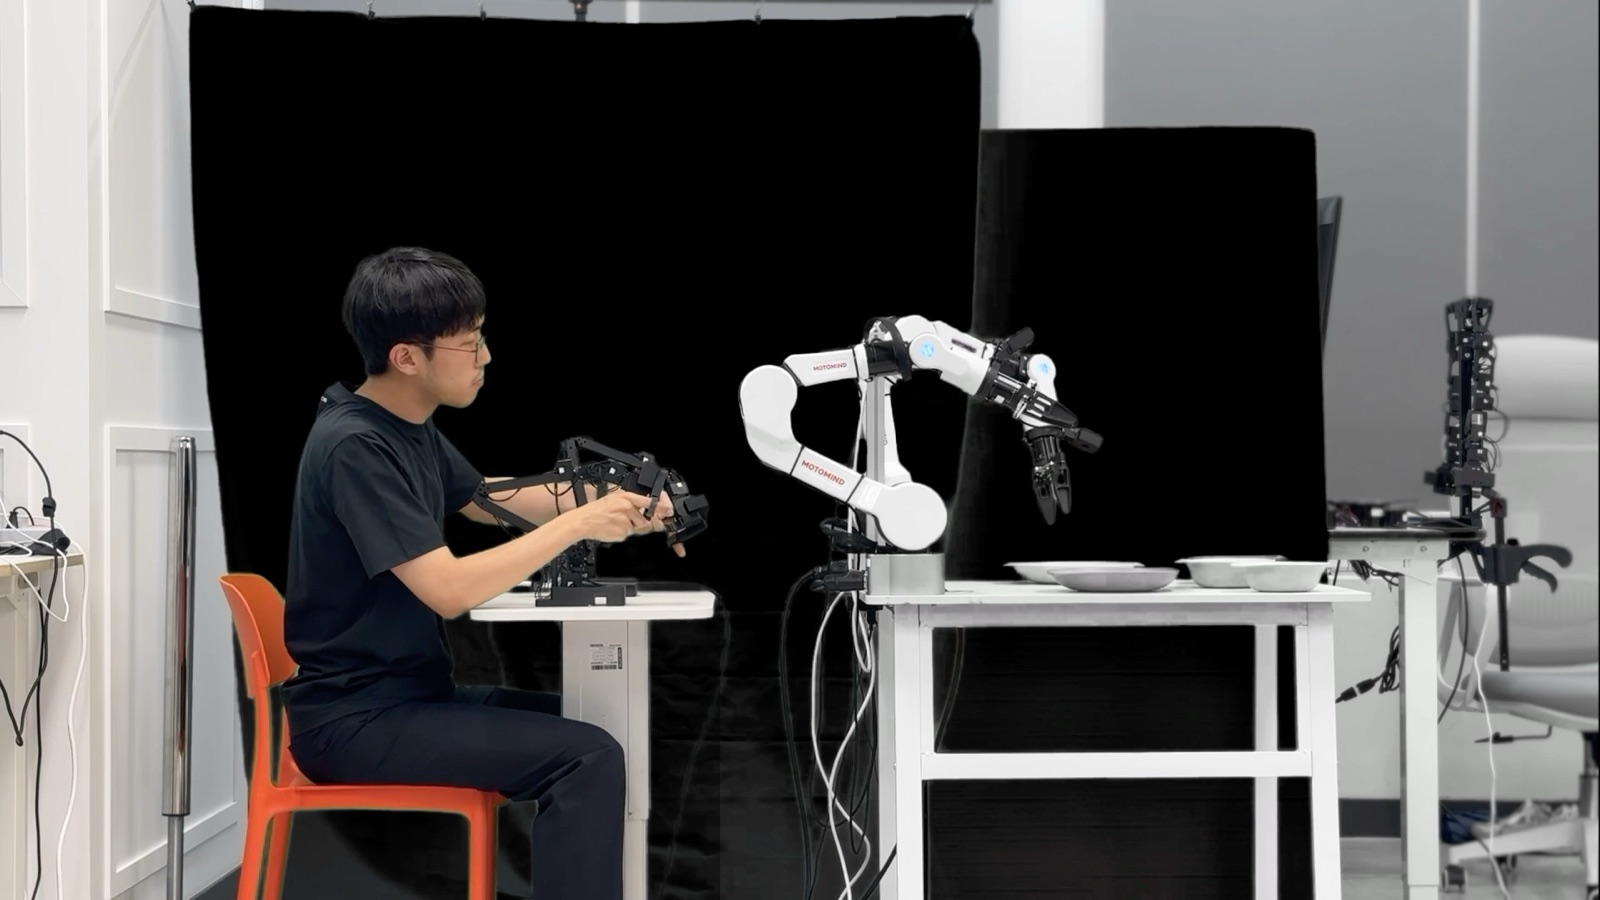
Haptic leader-arm teleoperation compensates for operator skill variance, turning the arm into a bed for standardized manipulation data capture.
Autonomous task validation
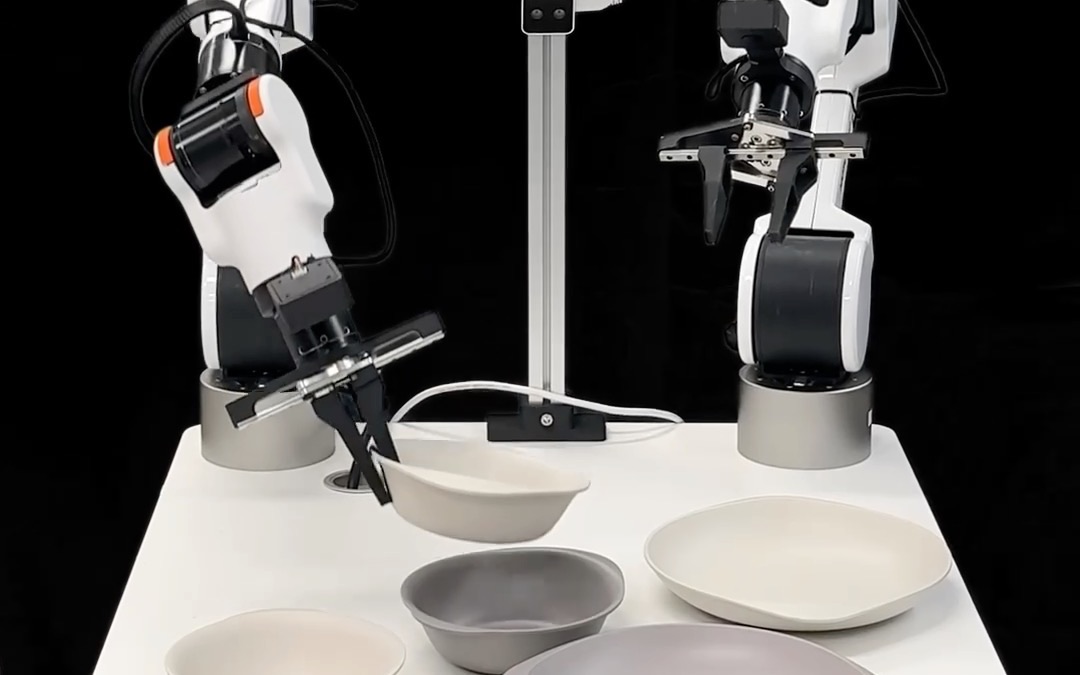
VLA policies trained on the collected data run unchanged on the dual-arm setup — tasks such as dish stacking that need ordering and placement decisions are executed autonomously and iterated quickly.
Service-robot integration
Integrates as the manipulator on mobile bases and service-robot platforms to deliver on-site services.
Education and research
Deployable as a robotics, reinforcement learning, or manipulation research platform for universities and labs.
Configurations
Fixed mount, mobile-base integration, or full humanoid integration — choose the configuration that fits the deployment.
Single 6+1 DOF
In productionSingle-arm module for fixed workstations or mobile-base integration.
- 6+1 DOF single arm
- Fixed or mobile base
- Selectable gripper module
BELLO Integrated
In productionMobile base and AI compute combined into the BELLO humanoid form factor.
- Humanoid integrated package
- On-board Jetson Orin AGX
- End-to-end solution
Software stack
In-house firmware and a standard robotics SW stack are shipped together, so the same interface carries from R&D into production without rework.
MOTOMIND SDK
Python and C++ SDK expose motion, torque, and safety APIs directly — no extra middleware required.
ROS2 driver
A ROS2 Humble driver package is included for drop-in integration with MoveIt2 and Nav2.
Teleoperation (TAS)
Pair with TAS to turn the same arm into a training-data capture rig — one module covers both R&D and operations.
VLA · imitation learning
Combined with the AI Board, the arm runs VLA and imitation-learning models on the edge in real time, without cloud dependency.
MILLY deployment evaluation
MOTOMIND supports process fit analysis, prototyping, and production collaboration.