
BELLO — 30 DoF AI Humanoid
A 30-DoF (degree-of-freedom) whole-body humanoid designed for industrial deployment. Pancake-motor low-reduction, high-torque actuators, an endoskeleton (internal-skeleton) structure, and on-board Jetson Orin AGX compute come together in one platform — whole-body control carries payloads up to 20 kg.
Specifications
Key features
Whole-body Control
Thirty degrees of freedom in coordinated control — 5 kg per arm alone, up to 20 kg when legs and torso distribute the load.
Low Reduction · High Torque · Lower BOM
High torque-density pancake motors and a low reduction ratio deliver torque and backdrivability, and wiring routed without a hollow shaft keeps cost down.
Shared Runtime
Task logic validated on MILLY runs unchanged through the common SDK and shared Runtime, cutting the iteration between development and deployment.
System composition
Perception, inference, and execution are integrated into a single platform.
Responsive dual-arm
A low reduction ratio lowers reflected inertia for fast response and smooth torque control.
Endoskeleton frame
An internal skeleton minimises exposed components to reduce collision risk, forming an affordable and safe arm system.
Cooperative high-torque joints
Two medium actuators cooperate in each thigh to drive high-torque joints, and identical parts are reused to reduce cost.
On-device AI · environment sensing
Jetson Orin AGX runs trained policies and vision models on-board, while LiDAR and RGB-D cameras perceive the workspace.
Applications
Expanding in stages — from structured logistics and food sites to manufacturing and, eventually, the home.
Logistics
Loading/unloading, sorting, and palletizing — repetitive handling of 5–20 kg objects.
Food processing
Ingredient feeding, packaging, and stacking of 3–15 kg items on structured food production lines.
Manufacturing
Part feeding, assembly assistance, and inspection transfer — 3–20 kg items and dual-arm coordination.
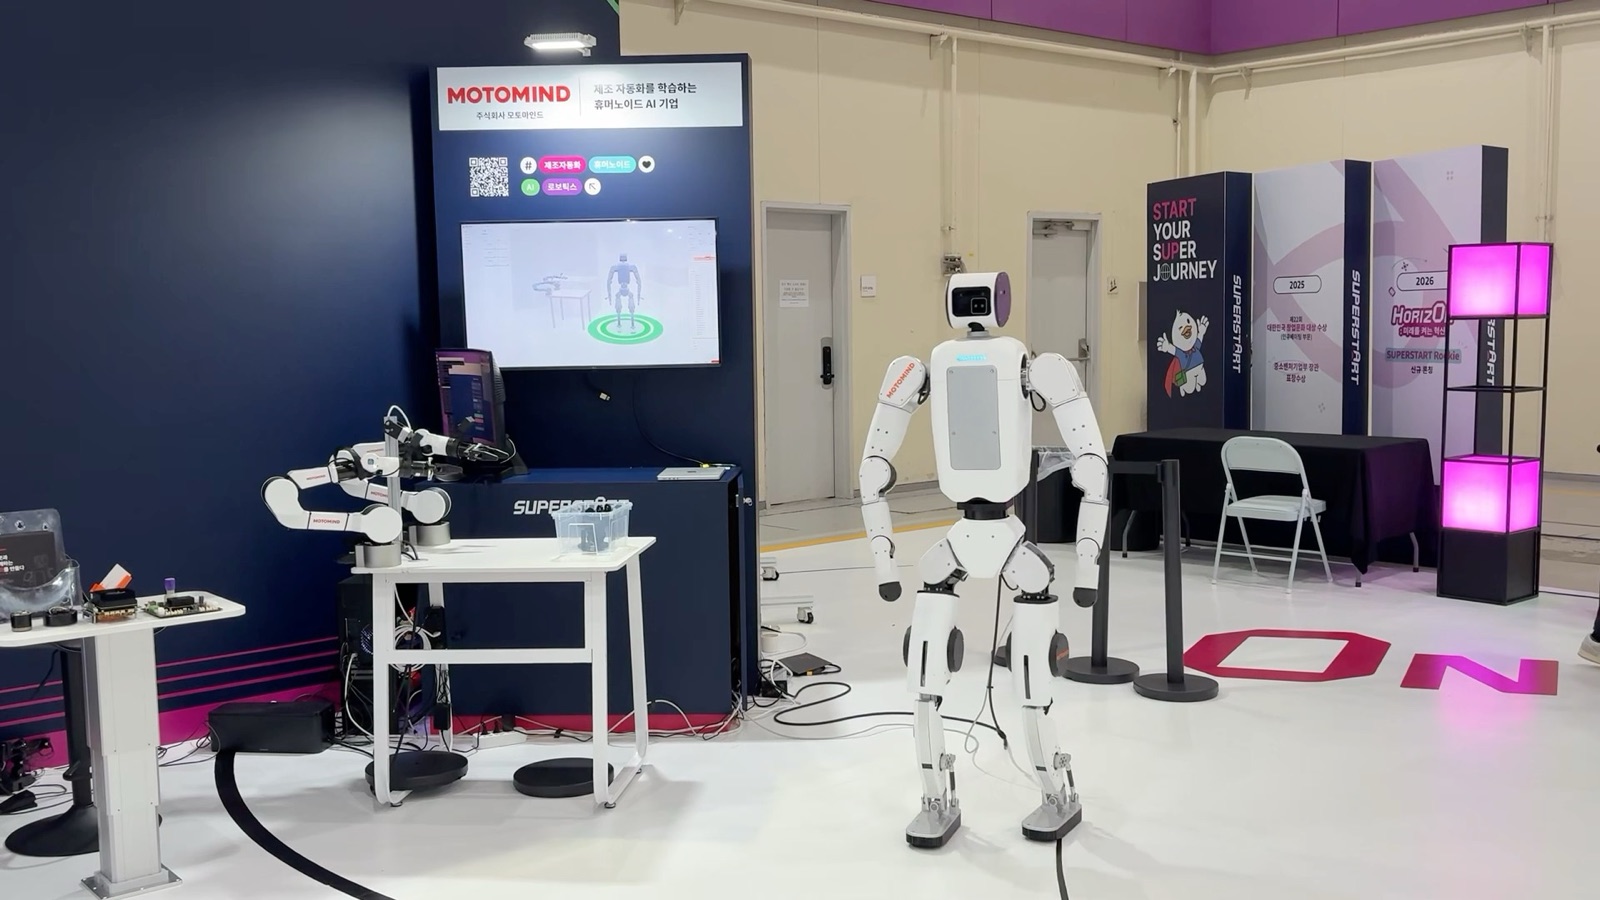
On-site demonstrations
BELLO walking and working live at exhibitions and validation sites.
Software stack
A shared Runtime handles inference and planning while BELLO's edge handles real-time control, connected to existing robotics stacks through the common SDK.
Cloud Physical AI Runtime
Trained policies run on a shared GPU Runtime with model version management — deployed on-premises or in the cloud depending on security requirements.
Python SDK · ROS2
A Python SDK, ROS2, and a common API integrate with existing robotics stacks and deploy the same task to other robots.
VLA · imitation-learning policies
Policies trained on demonstration and retargeting data from MILLY and BELLO mini deploy to BELLO through the same SDK contract, and operational data flows back into training.
Safety monitoring
Lidar / RGB-D collision avoidance, torque monitoring and emergency-stop interlocks are built in, removing the need for an external safety system.
BELLO deployment evaluation
MOTOMIND supports process analysis, deployment review, data capture, and staged rollout.