PRODUCT · BELLO mini

BELLO mini30 DoF Compact AI Humanoid

A 140 cm humanoid that inherits BELLO's actuators, endoskeleton structure, and AI stack unchanged. It handles 10 kg per arm and 30 kg with the whole body, and learns new tasks quickly by transferring an operator's full-body motion through VR. The field-validation platform for proving whole-body tasks and services on real hardware before industrial deployment.

30 DoF
Whole-body degrees of freedom
10 kg
Per-arm payload
30 kg
Whole-body payload
140 cm · 42 kg
Height · weight
01WHOLE-BODY PAYLOAD

10 kg per arm, 30 kg whole-body — lifting at a human operator's level

All thirty degrees of freedom are coordinated by one controller. Arms alone carry 10 kg each; spreading the load through leg and torso posture takes it to 30 kg. The validation — holding a 10 kg kettlebell in each hand while keeping posture — runs on the same low-reduction, high-torque actuators as BELLO.

DoF
30 DoF · whole-body coordination
Per-arm payload
10 kg
Whole-body payload
30 kg · load shared by legs and torso
Actuators
Low-reduction, high-torque pancake motors
Form factor
140 cm · 42 kg
10 kg kettlebells in both hands — payload validation with posture held
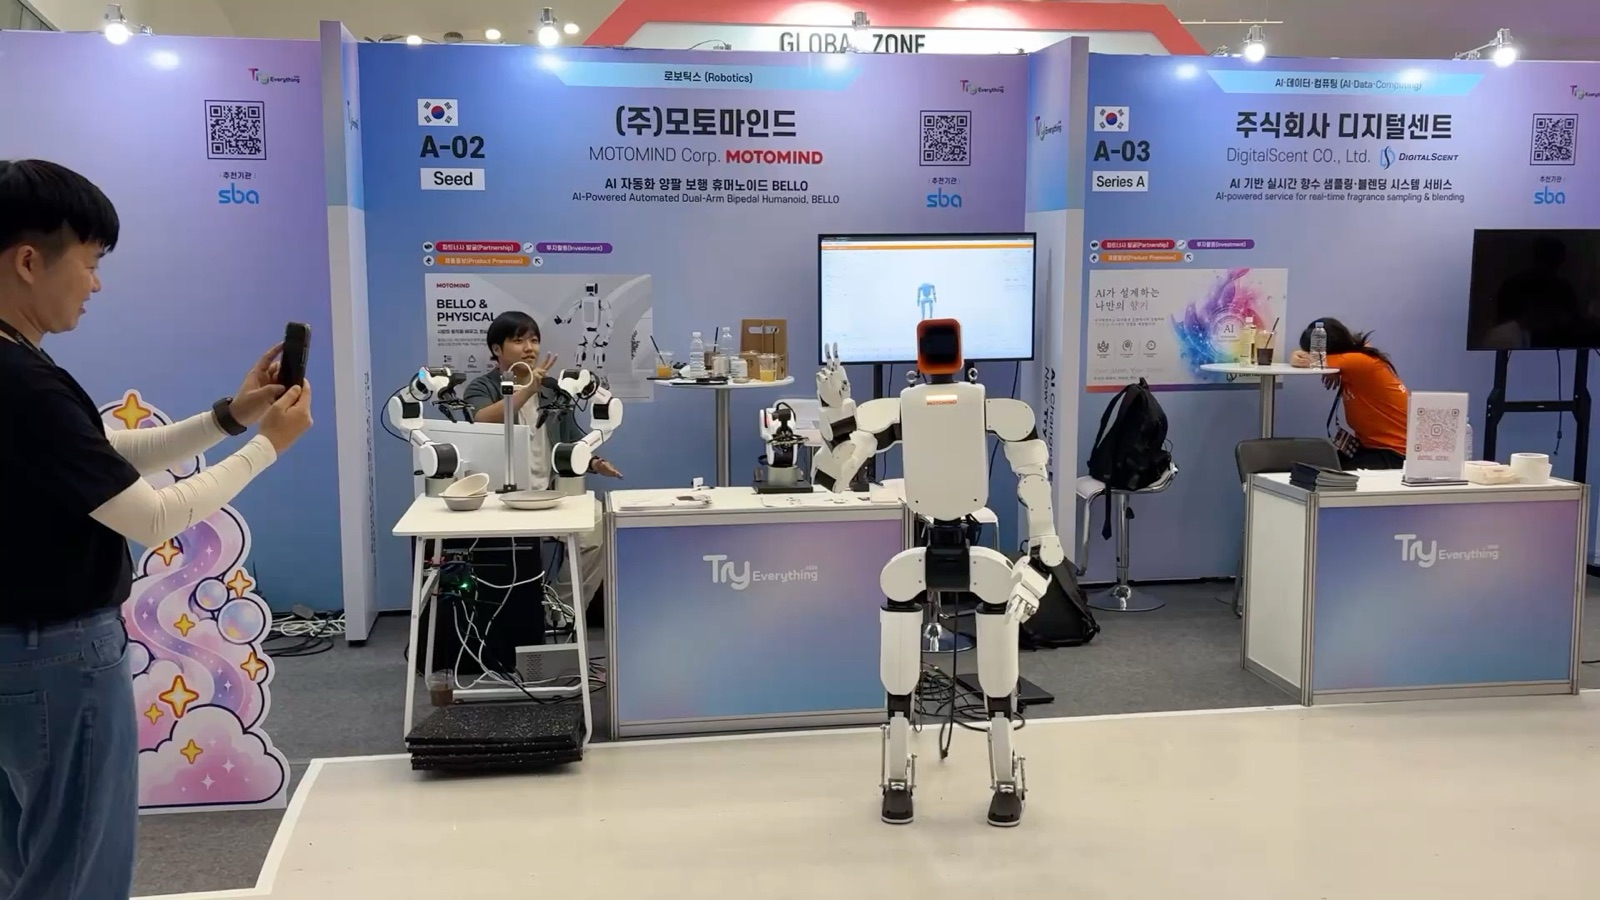
Exhibition booth demo — a 140 cm form factor that works beside people
02TEACHING · RETARGETING

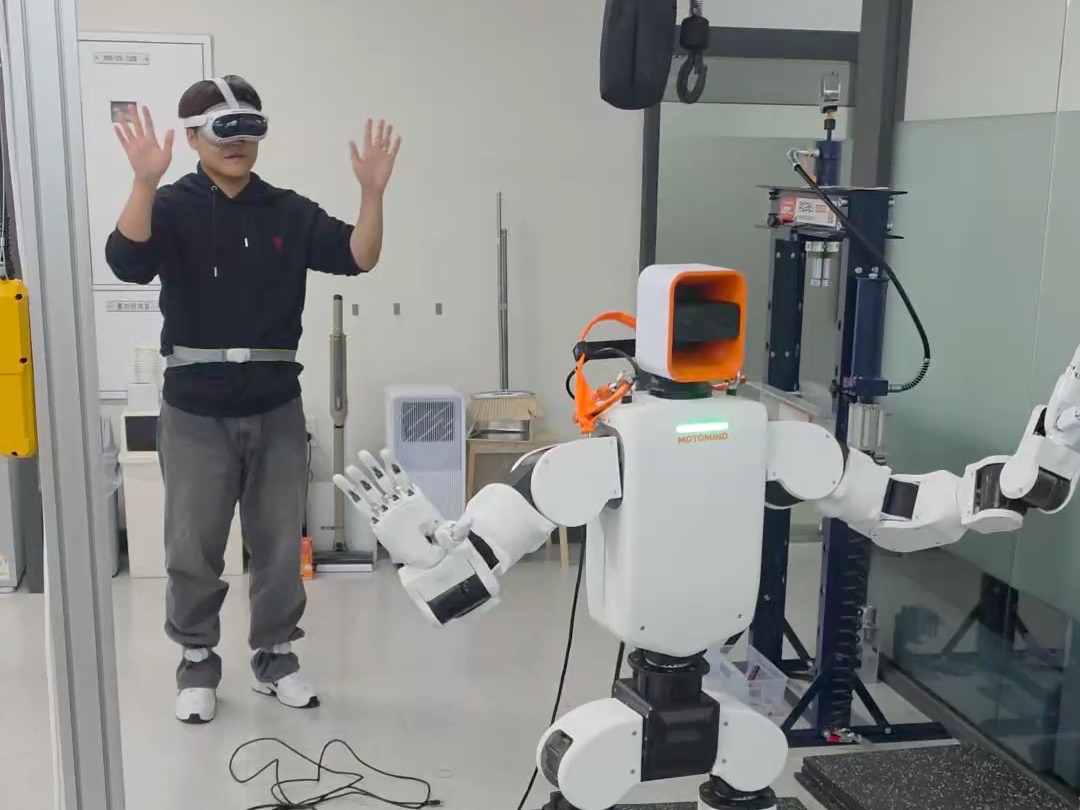
The operator's motion becomes the robot's motion

Full-body motion captured through VR and motion capture is retargeted in real time onto BELLO mini's joint structure. The retargeted motion is verified first in a simulator that reflects the real response of our actuators, then reproduced on the physical robot. The motion data accumulated along the way becomes the training set from which new tasks are learned.

Input
VR headset · controllers · motion capture
Retargeting
Real-time mapping across 30 joints
Verification
Simulator → reproduction on the real robot
Data
Retargeted motion accumulated as training data
Real-time retargeting of an operator's full-body motion — reproduced on the robot
The same motion verified in simulation
VR-based teleoperation — whole-body control from body-motion recognition
PLATFORM · SPECIFICATIONS

BELLO's core, unchanged — only smaller

Actuators, the endoskeleton structure, and the Jetson Orin AGX on-device AI stack are shared with BELLO. Reusing the same parts lowers cost and simplifies maintenance, and tasks validated on BELLO mini move to BELLO through the common SDK and shared Runtime.

Body
DoF
30 DoFWhole body
Height
140 cm
Weight
42 kg
Structure
EndoskeletonInternal skeleton · minimal exposed parts
Actuation · performance
Per-arm payload
10 kg
Whole-body payload
30 kgLoad shared by legs and torso
Actuators
Low-reduction, high-torquePancake motors · backdrivable
Dual arms
High-response endoskeleton armsSame module as BELLO
Compute · software
Compute
Jetson Orin AGXOn-device inference
Teaching
VR teleoperationBody-motion recognition · whole-body control
Learning
Retarget → simulate → real robot
Software
Common SDK · shared RuntimePython · ROS2
APPLICATIONS

Proven on real hardware before deployment

BELLO mini owns the stage before a robot enters an industrial site: whole-body tasks and service scenarios are validated on a physical robot, and the results and data carry forward to BELLO.

  1. 01

    Whole-body task validation

    Validate carrying and stacking tasks that need leg and torso posture on a real robot, and set the task criteria.

  2. 02

    Service scenario validation

    Implement service scenarios in the customer's domain and accumulate on-site results and operational data.

  3. 03

    Training-data platform

    Collect whole-body task data through VR teaching and retargeting, then run the trained policy on the same body to confirm it.

  4. 04

    Joint development · SI

    Build standard tasks and operating criteria that can be supplied repeatedly, together with industry SI partners.

BELLO mini deployment evaluation

MOTOMIND supports process analysis, deployment review, data capture, and a staged path to BELLO.