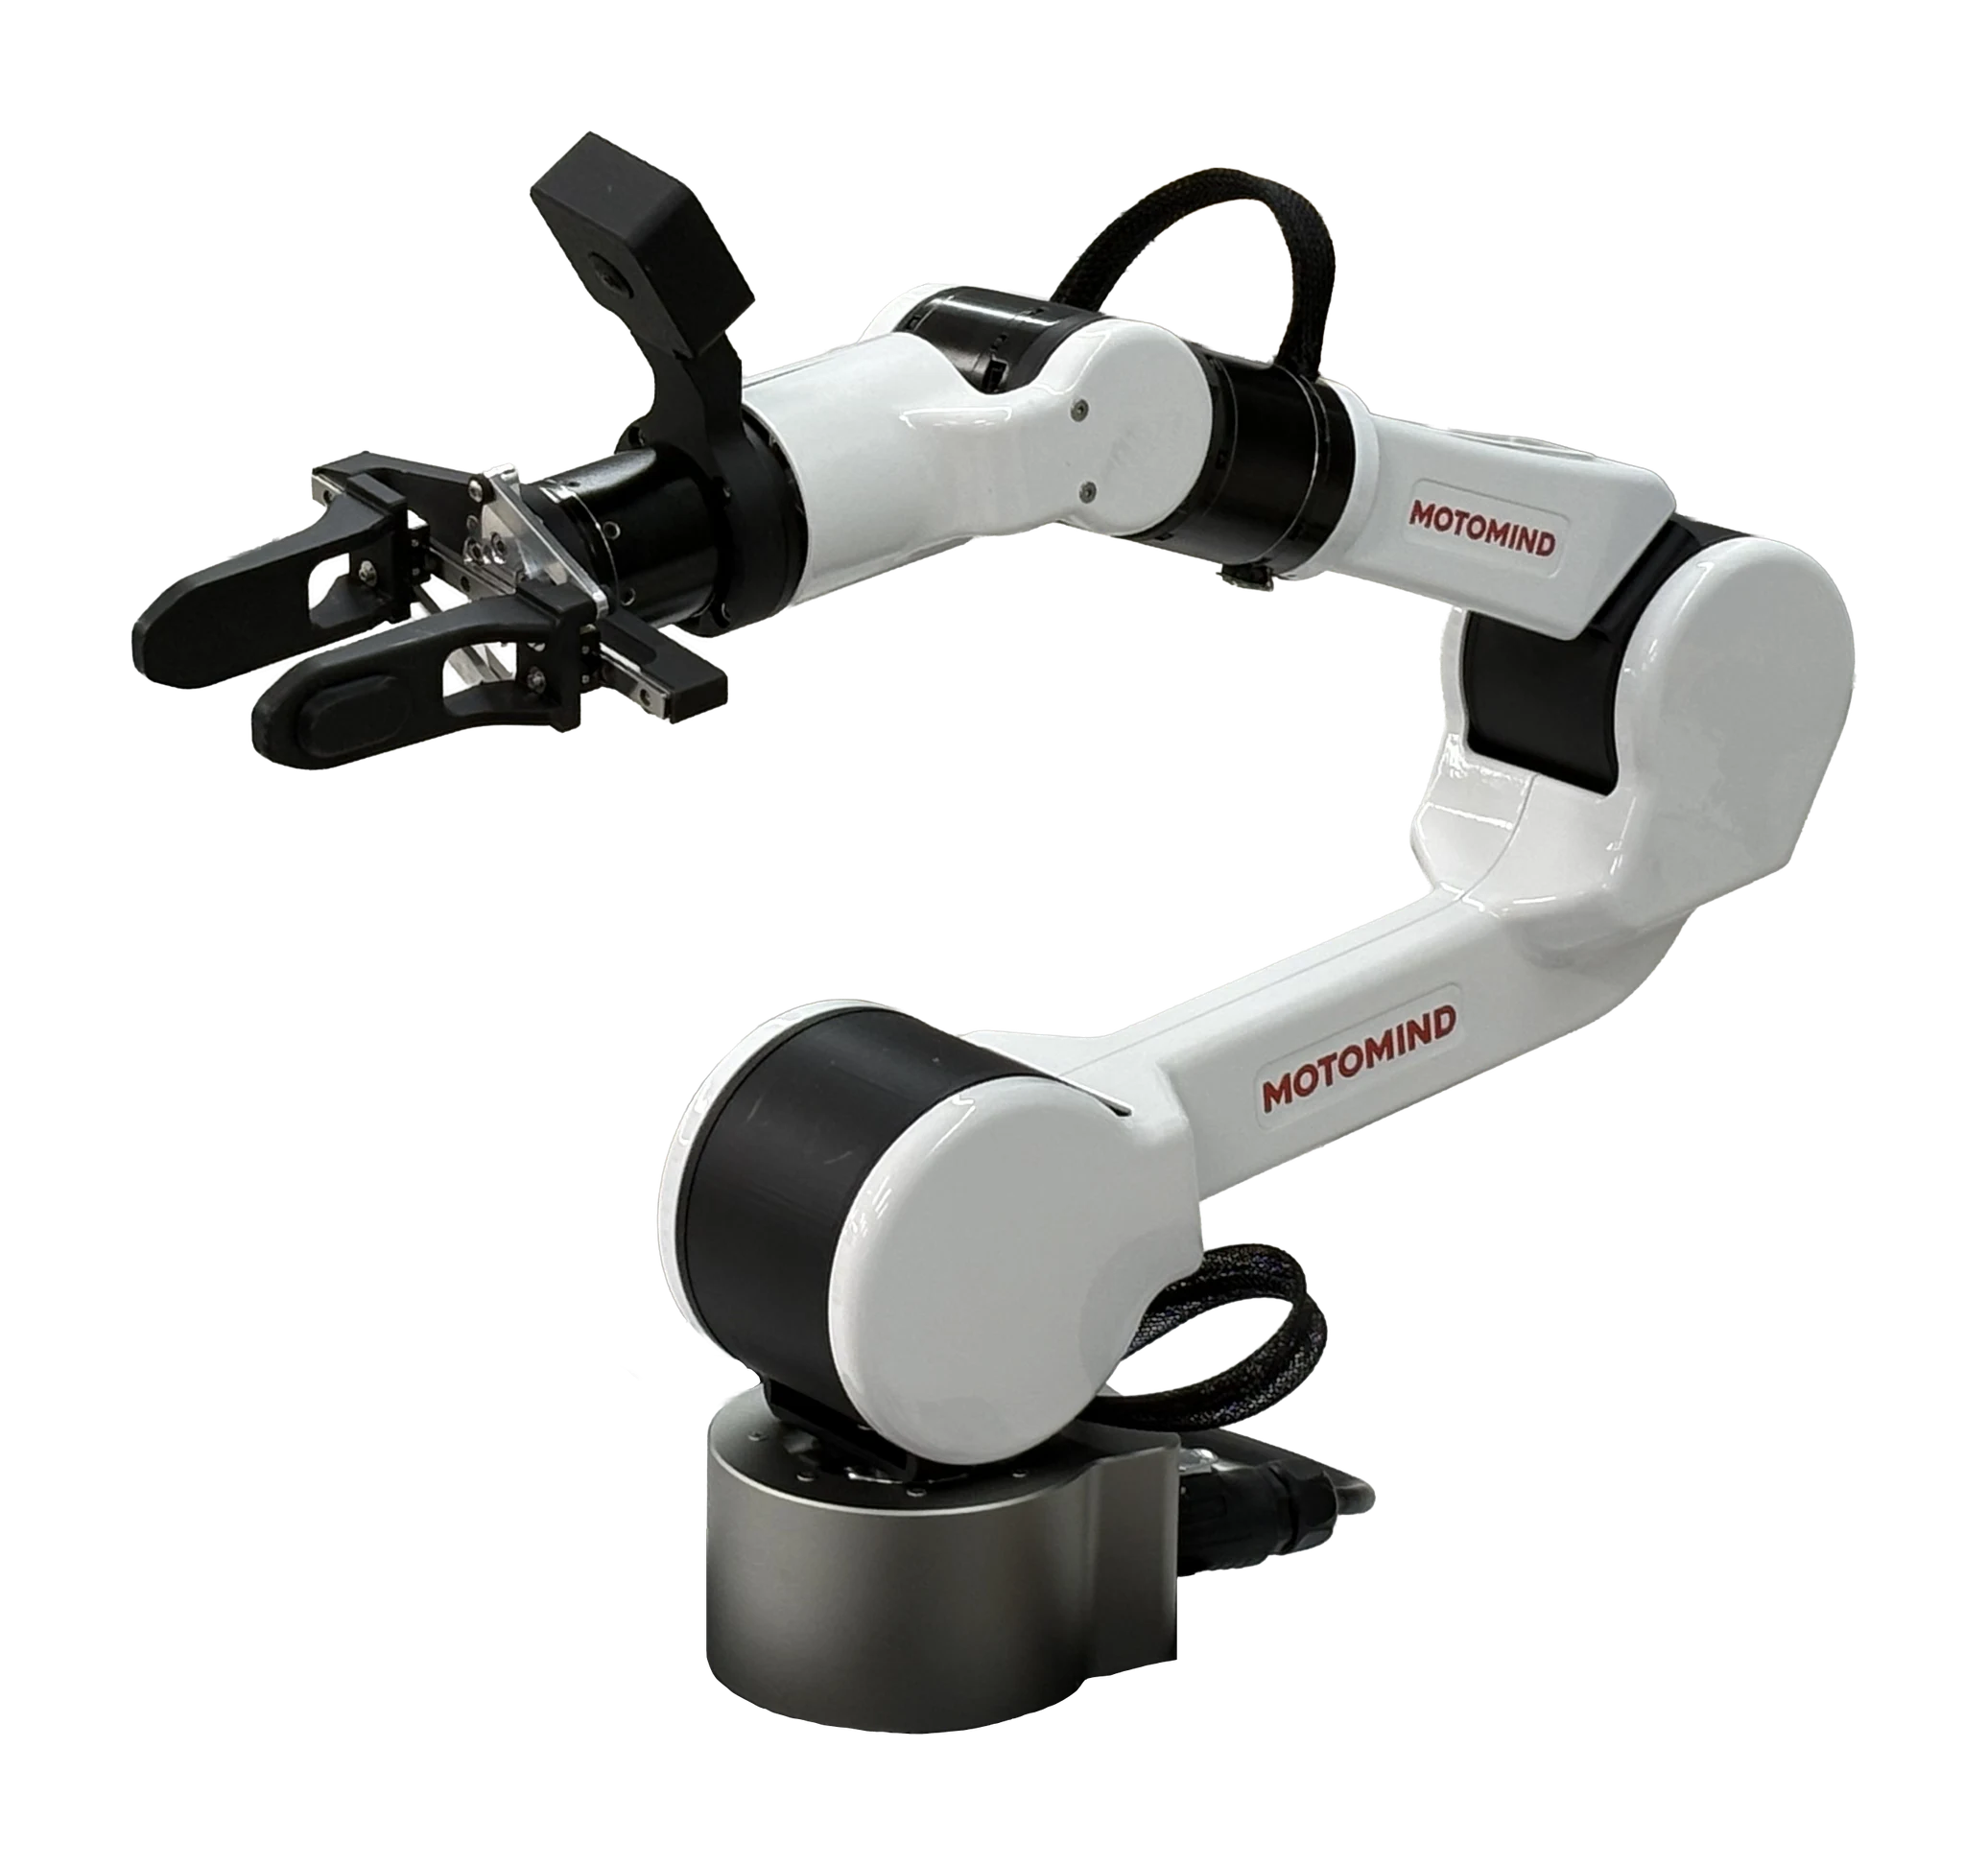
Robot Hardware
From the MILLY arm for validation and fast iteration to the BELLO humanoid for industrial deployment — actuators and structures designed and built in-house.

Robot hardware, AI, and a cloud runtime — all designed in-house and connected into one platform, so a task built once scales across more robots and more sites.
Physical AI has advanced quickly, yet in the field most deployments still stop at single-task demos. MOTOMIND builds the hardware, the AI, and the software in one team, so demos turn into repeatable day-to-day operations.
Instead of building hardware from scratch, customers start from robot hardware we design in-house — cutting development cost and time.
No need to build robot AI from the ground up: core AI capabilities are available directly through APIs and SDKs.
A task built once moves to other robots and sites as-is through a Python SDK, ROS2, and a common API.
From the MILLY arm for validation and fast iteration to the BELLO humanoid for industrial deployment — actuators and structures designed and built in-house.
A loop of data collection, policy training, simulation validation, and redeployment that turns field experience back into learning.
A shared AI Runtime handles inference and planning while each robot's edge handles real-time control — deployed across robots and sites through a common SDK.
LOW REDUCTION · HIGH TORQUE · LOWER BOM. Low-reduction, high-torque actuators and an endoskeleton structure keep cost down, while whole-body control and bipedal walking widen the work envelope.
From an AI robot arm for R&D, to BELLO mini for field validation, to BELLO for industrial operation. Every product runs on the same AI Driver and common SDK, so a task built on one carries over to the next.
From actuators to the edge board, the learning pipeline, and the shared runtime — every layer is developed in-house. A human demonstration becomes a robot task, and a task one robot has learned carries over to other robots and sites.
Low-reduction, high-torque actuators and an endoskeleton structure. The same modules are reused from the MILLY arm to the BELLO humanoid.
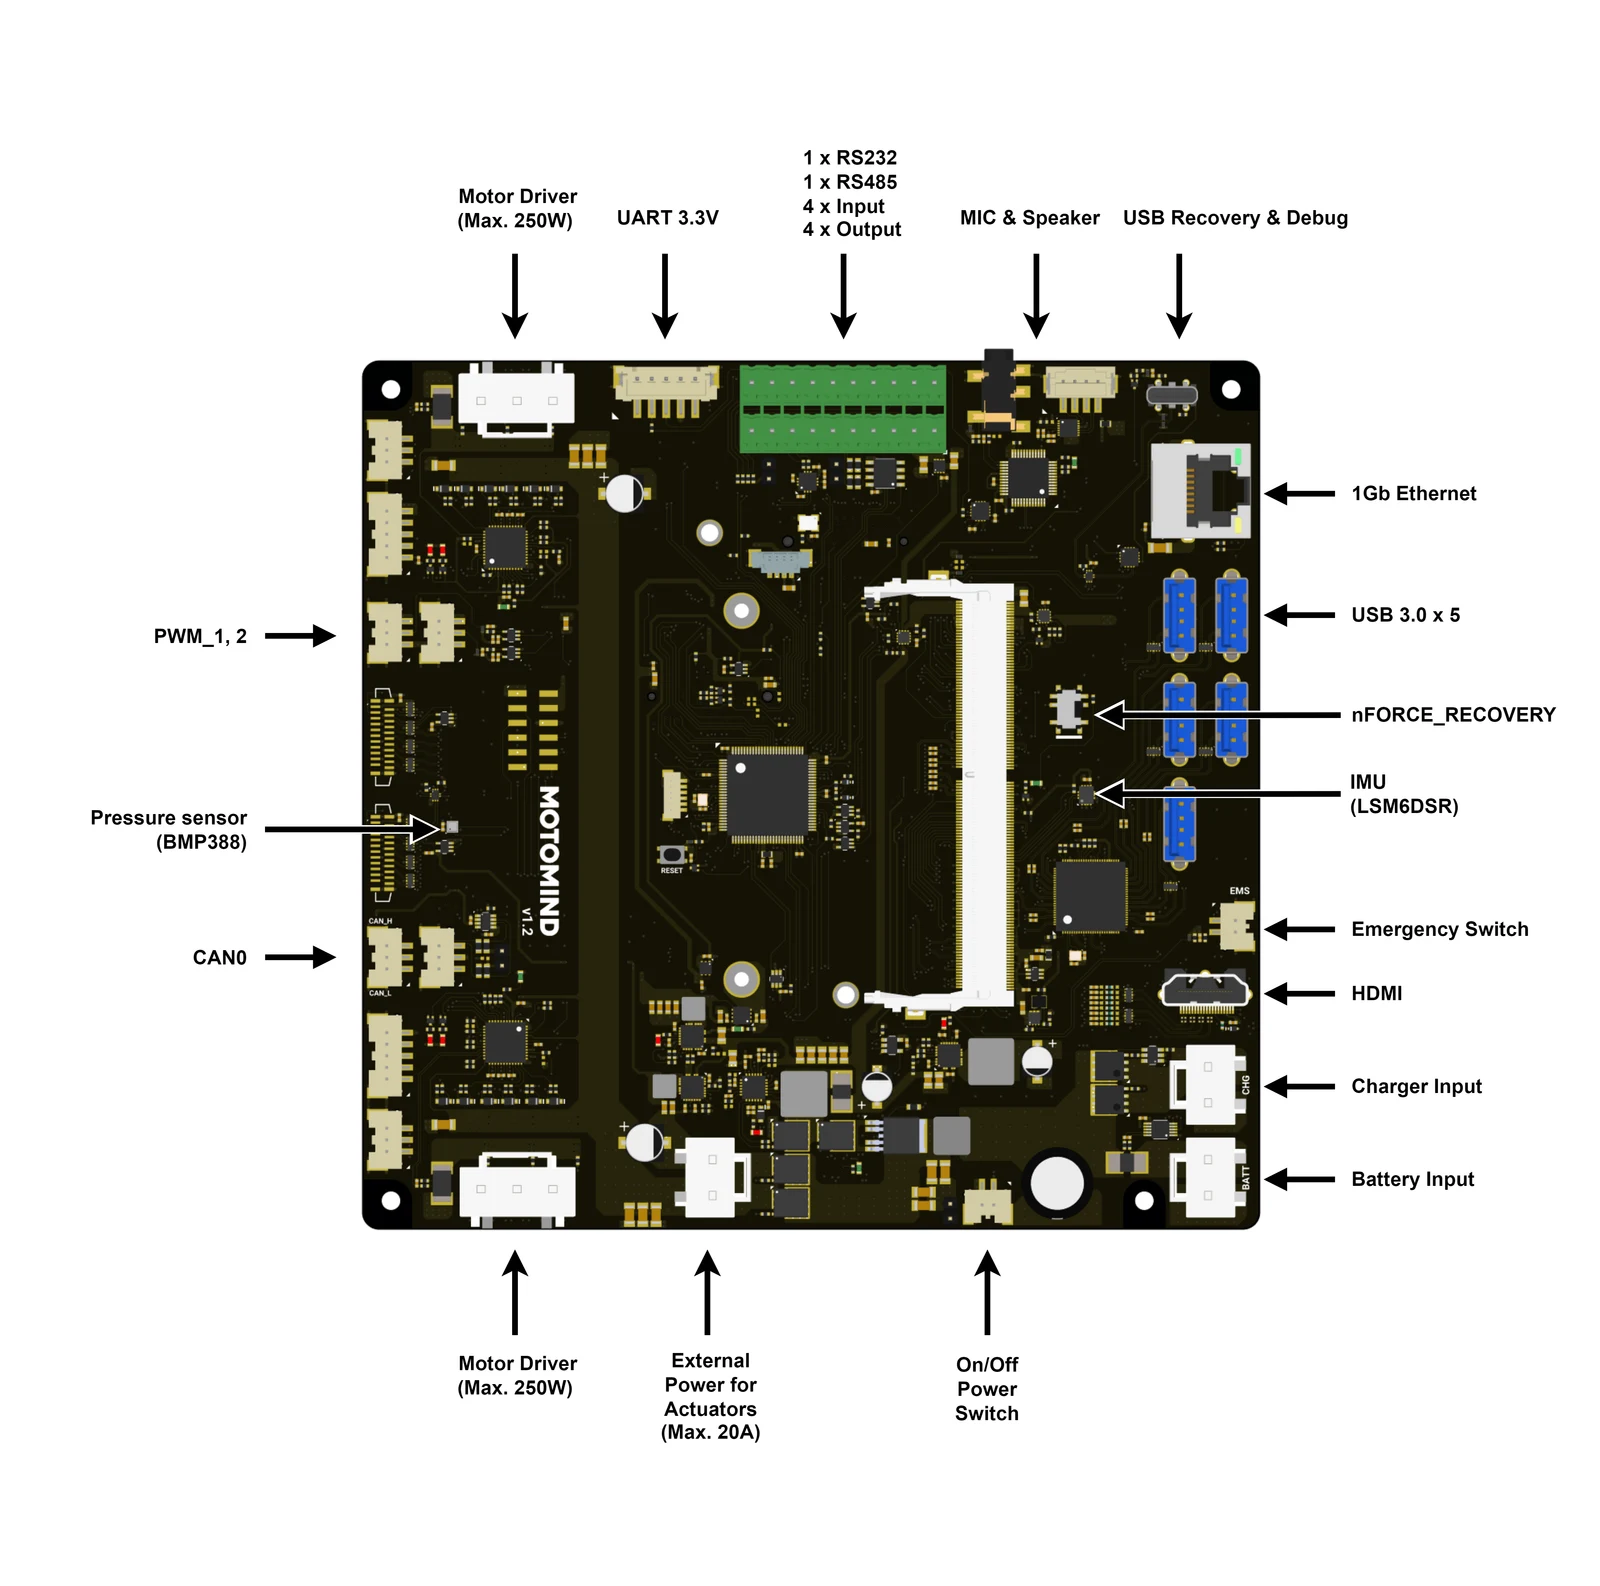
A common edge layer that integrates motor drivers, IMU, a real-time MCU, and CAN onto a single Jetson carrier board.
Teleoperated demonstrations are collected as data, retargeted onto the robot's body, verified in simulation, then executed on the real robot.
A shared AI Runtime handles inference and planning while each robot's edge handles real-time control. A common SDK deploys tasks across robots.
We research and validate alongside universities, research institutes, and industry partners to bring Physical AI into real sites.

Recent press releases, partnership announcements, and product updates.
MOTOMIND Inc. is a robotics company that turns Physical AI into real-world work.
Incorporated in February 2026, MOTOMIND is building a Physical AI platform that spans robot hardware (MILLY · BELLO), the AI Driver, a Cloud Physical AI Runtime, and a Learning Flywheel.
From a headquarters at Changeup Ground in Pohang, a corporate R&D center at GIDC in Gwangmyeong, and a factory in Gyeongju, we handle everything from prototyping to pilot-production validation ourselves.
Key milestones from the POSTECH Startup Grand Prize (2023) through incorporation, BELLO's bipedal walking, and TIPS selection.
MOTOMIND operates a headquarters at Changeup Ground (Pohang) and a corporate R&D center at GIDC (Gwangmyeong), and validates pilot-production units at its factory in Gyeongju.
From hardware adoption and demos to joint development, PoCs, SI partnerships, and careers — leave us a note and we'll respond within 1–2 business days.
contact@motomind.co.kr