
Product lineup
From R&D to field validation to industrial operation — robot hardware and the AI Driver for each stage, all running on the same common SDK and shared Runtime.
BELLO mini
A 140 cm humanoid inheriting BELLO's core technology — the validation platform for whole-body tasks, services, and joint development / SI projects.
With a 10 kg one-arm and 30 kg whole-body payload it handles work close to a human operator's. VR-based teleoperation recognizes the operator's body motion to drive the whole body, and a generate-retarget-validate pipeline from human motion lets it pick up new tasks quickly.
- 30 DoF whole body
- 10 kg per arm · 30 kg whole-body
- 140 cm · 42 kg form factor
- VR-based whole-body teleoperation
BELLO
A human-scale humanoid for industrial sites such as logistics, food, and manufacturing — placed without major changes to existing benches and processes.
A 30-DoF humanoid integrating pancake-motor low-reduction, high-torque actuators, endoskeleton dual arms, and on-board Jetson Orin AGX compute. Whole-body control carries up to 20 kg, and task logic validated on MILLY runs unchanged through the common SDK and shared Runtime.
- 30 DoF whole body
- Up to 20 kg payload (whole-body)
- 170 cm · 50 kg form factor
- Jetson Orin AGX
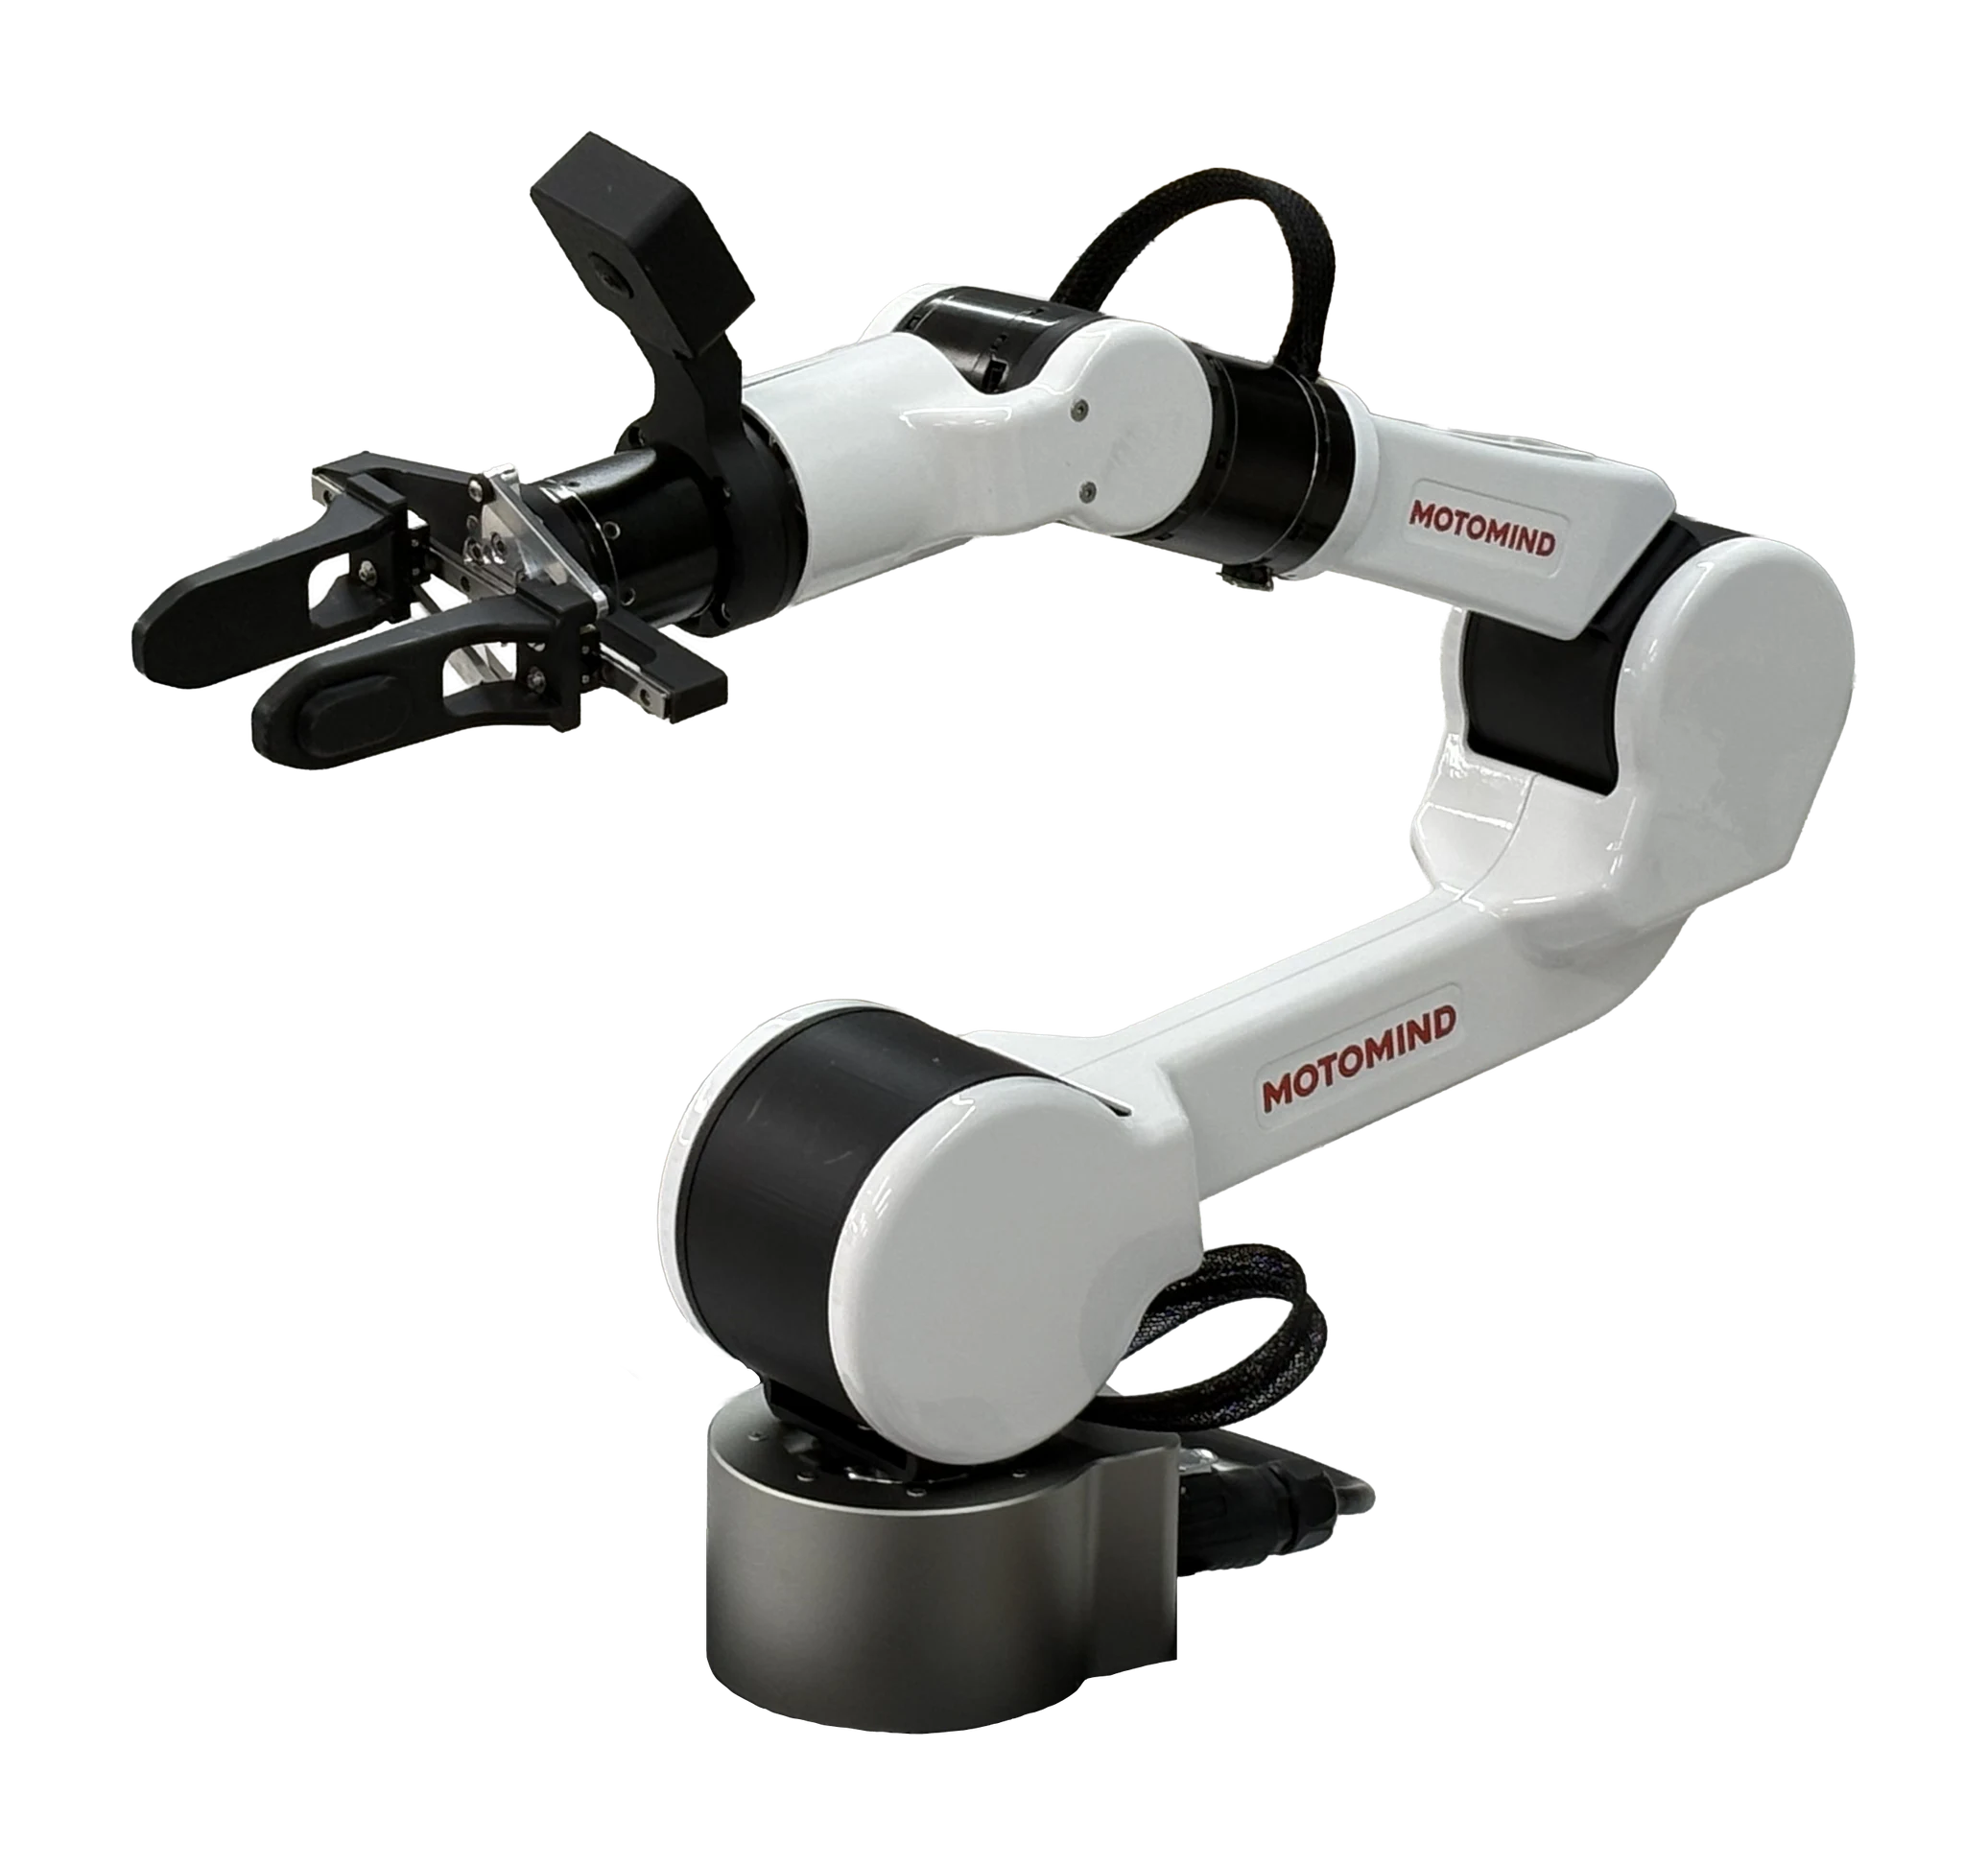
MILLY
An in-house AI robot arm with an internal skeleton, used by universities, labs, startups, and B2B teams for manipulation validation and fast iteration.
A 6+1 DoF single arm — six joints plus one gripper/tool axis — with low-ratio actuators, torque-monitored auto-stop on collision, and swappable grippers. Task logic and data built on MILLY carry straight over to BELLO through the common SDK.
- 6+1 DoF single arm
- 3 kg payload
- Endoskeleton frame
- High-response actuator

AI Board
An NVIDIA Jetson-based edge device integrating motor drivers, navigation sensors such as IMU and barometer, CAN / RS485, and a high-performance compute socket on a single board.
The common edge execution layer of the MOTOMIND platform, handling sensing, real-time control, and data collection. Jetson Nano and AGX socket boards are complete and a Thor socket board is in development — applied with the same architecture to mobile robots, VLA platforms, and humanoids.
- IMU · barometer · motor drivers
- 40 – 275 TOPS
- Nano · AGX socket boards ready
- Thor socket board in dev.